Title : Autonomous Discovery for Autonomy
Talk Abstract :
Prof. Manmohan argued that autonomy is a long-tail problem. This makes it less an automotive challenge than a continuous software one, slowed down by cost, compliance, weak traceability, and skill gaps. He proposed making autonomy development "AI-native" by handing the whole research and development loop - implementation, innovation, and discovery - to multi-agent systems, while keeping human-level rigour. He showed a system that turned paper specifications into fully executable NeRF code, coming within 0.5 dB PSNR of expert human implementations, where generic coding agents managed only about 26% executability and paper-to-code systems around 5%. He then described a 36-agent pipeline for 3D Gaussian Splatting research, in which ideas competed in an ELO-rated "knowledge discovery arena" and were judged on real training runs rather than model opinion, producing full papers in two days for roughly $250 of compute, 75% of which were accepted at CVPR workshops before being withdrawn by prior agreement. He closed by arguing that no world model alone will solve the long tail, and that what autonomy really needs is executability, verifiability, and auditability - a future with 10,000 agents rather than 10,000 GPUs.
Biography:
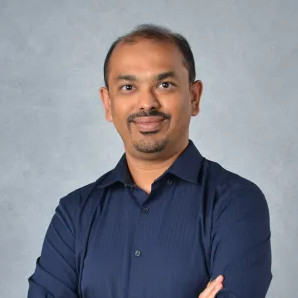
Prof: Manmohan Chandraker is a full professor in the CSE department of University of California, San Diego. His interests are in computer vision and machine learning, with applications in self-driving and augmented reality. His work has been recognized with the Best Paper honorable mention at ECCV 2022, Google Research Awards in 2021, 2019 and 2018, the NSF CAREER Award in 2018, the Best Paper Award at CVPR 2014, an IEEE PAMI special issue on Best Papers from CVPR 2011, the 2009 CSE Dissertation Award for Best Thesis from UCSD and the Marr Prize honorable mention at ICCV 2007.